The Agrofelis A3 Robot

Our third-generation autonomous robot at work in olive orchards and vineyards, by day and by night, and the fabrication, prototyping and interfaces behind it.

Our Work in Action

Explore Agrofelis A3 in the fields

  • All
  • Orchard
  • Vineyard
  • Night Operations
  • Fabrication
  • Prototyping
  • Interfaces
  • Events
Agrofelis A3 navigating olive orchard rows autonomously

Olive Orchard Navigation

Precision autonomy in sloped olive groves, tackling weeds with AI vision

Agrofelis A3 inspecting olive trees for pests

Olive Tree Inspection

Real-time AI detection spotting early threats, reducing chemical needs by up to 95%

Rear view of the Agrofelis A3 robot in an olive grove

Olive Tree Inspection

Real-time AI detection spotting early threats, reducing chemical needs by up to 95%

Agrofelis A3 in olive orchard terrain

Orchard Terrain Mastery

Hybrid-powered stability on uneven ground, optimized for Mediterranean slopes

Agrofelis A3 performing ULV spraying in vineyard

Vineyard Precision Spray

ULV tech in action, cutting water use by 90% while protecting your vines sustainably

Agrofelis A3 scouting vineyard pests

Vineyard Pest Scout

Machine vision at work, identifying issues with 95% accuracy for targeted response

Agrofelis A3 in full vineyard operation

Vineyard Full Ops

End-to-end autonomy from dawn patrols to dusk, hybrid power for non-stop efficiency

Agrofelis robot with lights for night operations

Night Operations

Agrofelis equipped with lights to operate efficiently at night, enabling 24/7 field tasks

Agrofelis performing ULV spray at night

Night ULV Spray

Shows the actual mist not visible at daylight, demonstrating precision spraying in low-light conditions

Front wheels during Agrofelis construction

Front Wheels Construction

Shows the front wheels during fabrication, highlighting robust design for terrain handling

Custom rotating implement component of the Agrofelis robot

Rotating Implement

Show the rotating implement custom component, enabling versatile tool attachments

Agrofelis steering assembly with two rear wheels

Steering Component

The steering component with two rear wheels, designed for precise maneuverability in tight spaces

Agrofelis steering assembly, detail B

Steering Detail

Alternative angle of steering with rear wheels, emphasizing durability

Agrofelis steering assembly, detail C

Steering Detail B

Close-up of steering mechanics, built for sloped terrain navigation

Bare metal frame of Agrofelis

Bare Metal Frame

Shows the bare metal frame, the sturdy backbone of the robot's structure

Custom plasma cutter for prototyping

Custom Plasma Cutter

Shows our custom-built plasma cutter to aid prototyping and frame fabrication

Welding the steel frame of the Agrofelis robot

Welding Fabrication

Shows the welding process in building Agrofelis components for durable frame assembly

3D schematics of Agrofelis A3 model

3D schematics of Agrofelis A3 model

Detailed 3D schematics of the A3 prototype, showcasing design and engineering

Prototyping long range communications and differential GPS

Long Range Comms & GPS

Shows prototyping of long-range communications and differential GPS for accurate positioning

DMD CAN PCB detail B

DMD CAN Detail

Detailed prototyping of DMD CAN PCB

DMD CAN PCB detail C

DMD CAN Detail B

Alternative view of DMD CAN PCB prototyping B

DMD CAN PCB detail D

DMD CAN Detail D

Further DMD CAN PCB prototyping detail D

3D printing in prototyping

3D Printing Prototyping

Various 3D printed parts in the prototyping process

3D printing detail B

3D Printing Detail B

Specific 3D printing components for robot prototyping

3D printing for sensors

3D Printed Sensors

Prototyping sensor mounts and enclosures using 3D printing

CNC machining in prototyping

CNC Prototyping

Using CNC for precision prototyping of metal components

Prototyping the Agrofelis machine vision system

Machine Vision Prototyping

Testing and developing machine vision systems for detection and navigation

Prototyping the Agrofelis remote control unit

Remote Prototyping

Prototyping remote control systems for operator oversight

Agrofelis remote control unit prototype, detail

Remote Detail B

Detailed view of remote prototyping components B

Agrofelis A2 robot control interface

A2 Interface

Evolved A2 interface with improved controls and features

Agrofelis A3 robot monitoring and control interface

A3 Interface

Refined A3 interface with enhanced monitoring and controls

Agrofelis live video streaming interface for remote operation

Video Interface

Real-time video streaming interface for remote operation

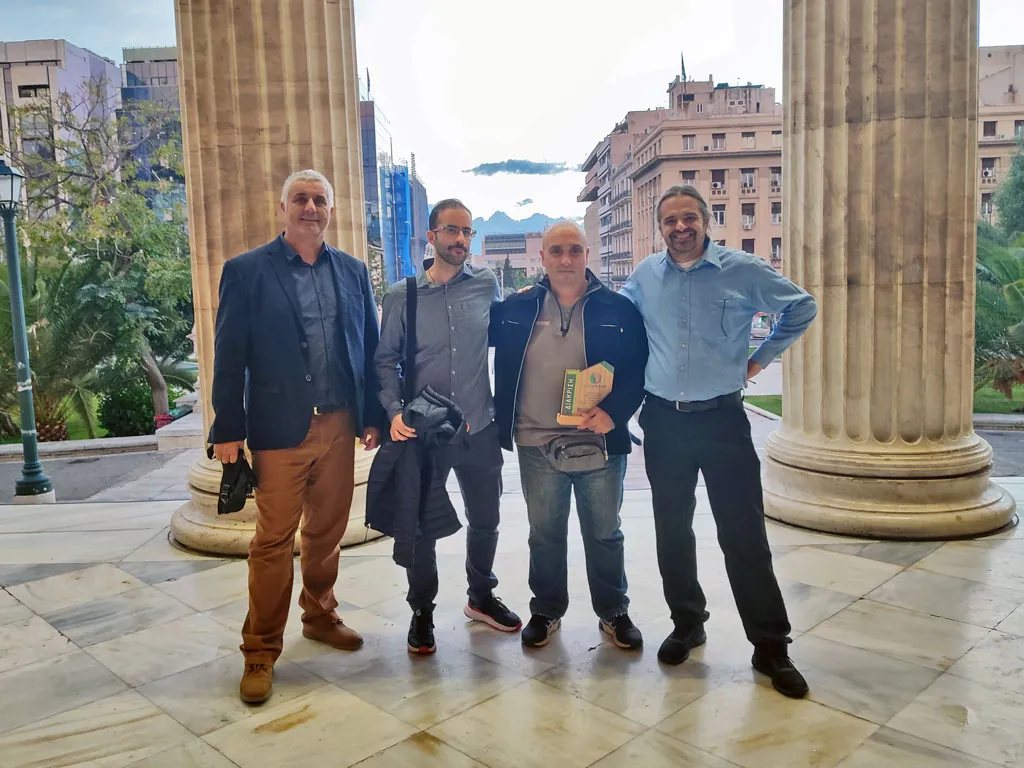
Agrofelis team receiving the Innovate East award

Innovate East Award

Agrofelis received an award from Innovate East

Agrofelis team at the EIC Accelerator event

EIC Accelerator Event

Agrofelis team at the EIC Accelerator event, networking and showcasing

Agrofelis robot climbing an uphill vineyard slope

Uphill Vineyard Test

Testing Agrofelis on uphill vineyard terrain for stability and performance

Agrofelis robot during a vineyard field test

Vineyard Test

Agrofelis undergoing field testing in vineyard environment